- Welcome to Pulse Robot
- +86-23-63207381
- +8613677602178
- sales@pusirobot.com
Nema17 Integrated Stepper Linear Actuator

Nema17 Integrated Stepper Motor Actuator
Main characteristics
Nema17 Linear Actuator is a high-performance linear push rod that integrates a ball screw, guide rail, limit switches, drive controller, and encoder. It delivers superior positioning accuracy, longer service life, and high thrust output. The actuator supports CANopen standard protocol and MODBUS RTU bus control, operates on a wide 9–36V DC supply, and offers multiple motion control modes, making it suitable for nearly all applications.
Technical data
General
|
Linear Push-Rod All-in-One Series
|
|
| Positioning accuracy |
0.01mm
|
| Stroke | Min 10mm, Max 300mm (custom lengths available upon request)
|
| Lead |
2mm, 4mm
|
| Speed |
0-30mm/s (lead 2mm)
0-60mm/s (lead 4mm) |
| Supply voltage |
DC9-36V
|
| Max. static load |
3200N
|
| Max. dynamic load |
3000N
|
| Operating temperature |
-40℃-85℃
|
| Durability |
> 20,000 hours
|
| Weight |
1680g
|
| Motor rated current |
1600mA
|
The input
| General I/O |
Linear Push-Rod All-in-One Series
|
| Function |
External stop input, electromagnetic brake control, digital I/O, analog input, factory reset, 5V output, digital ground.
|
| Input Specifications |
Digital input voltage: 0–5 V
Analog speed control input voltage: 0–3.3 V External limit input voltage: 0–5 V |
Control mode
|
Linear Push-Rod All-in-One Series
|
|
| Supported Control Modes |
Position mode, velocity mode, PV mode, PP mode, analog speed control, analog positioning, and synchronous positioning.
|
| Mode Switching |
Via dedicated commands
|
Communication
|
Linear Push-Rod All-in-One Series
|
|
| protocol |
CANopen DS301/ MODBUS-RTU
|
| Baud rate |
5K-1M bps adjustable / 9600-115200 bps adjustable
|
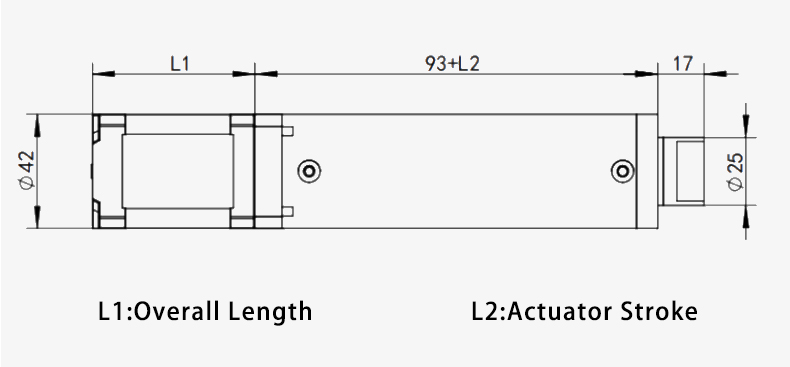
Dimension
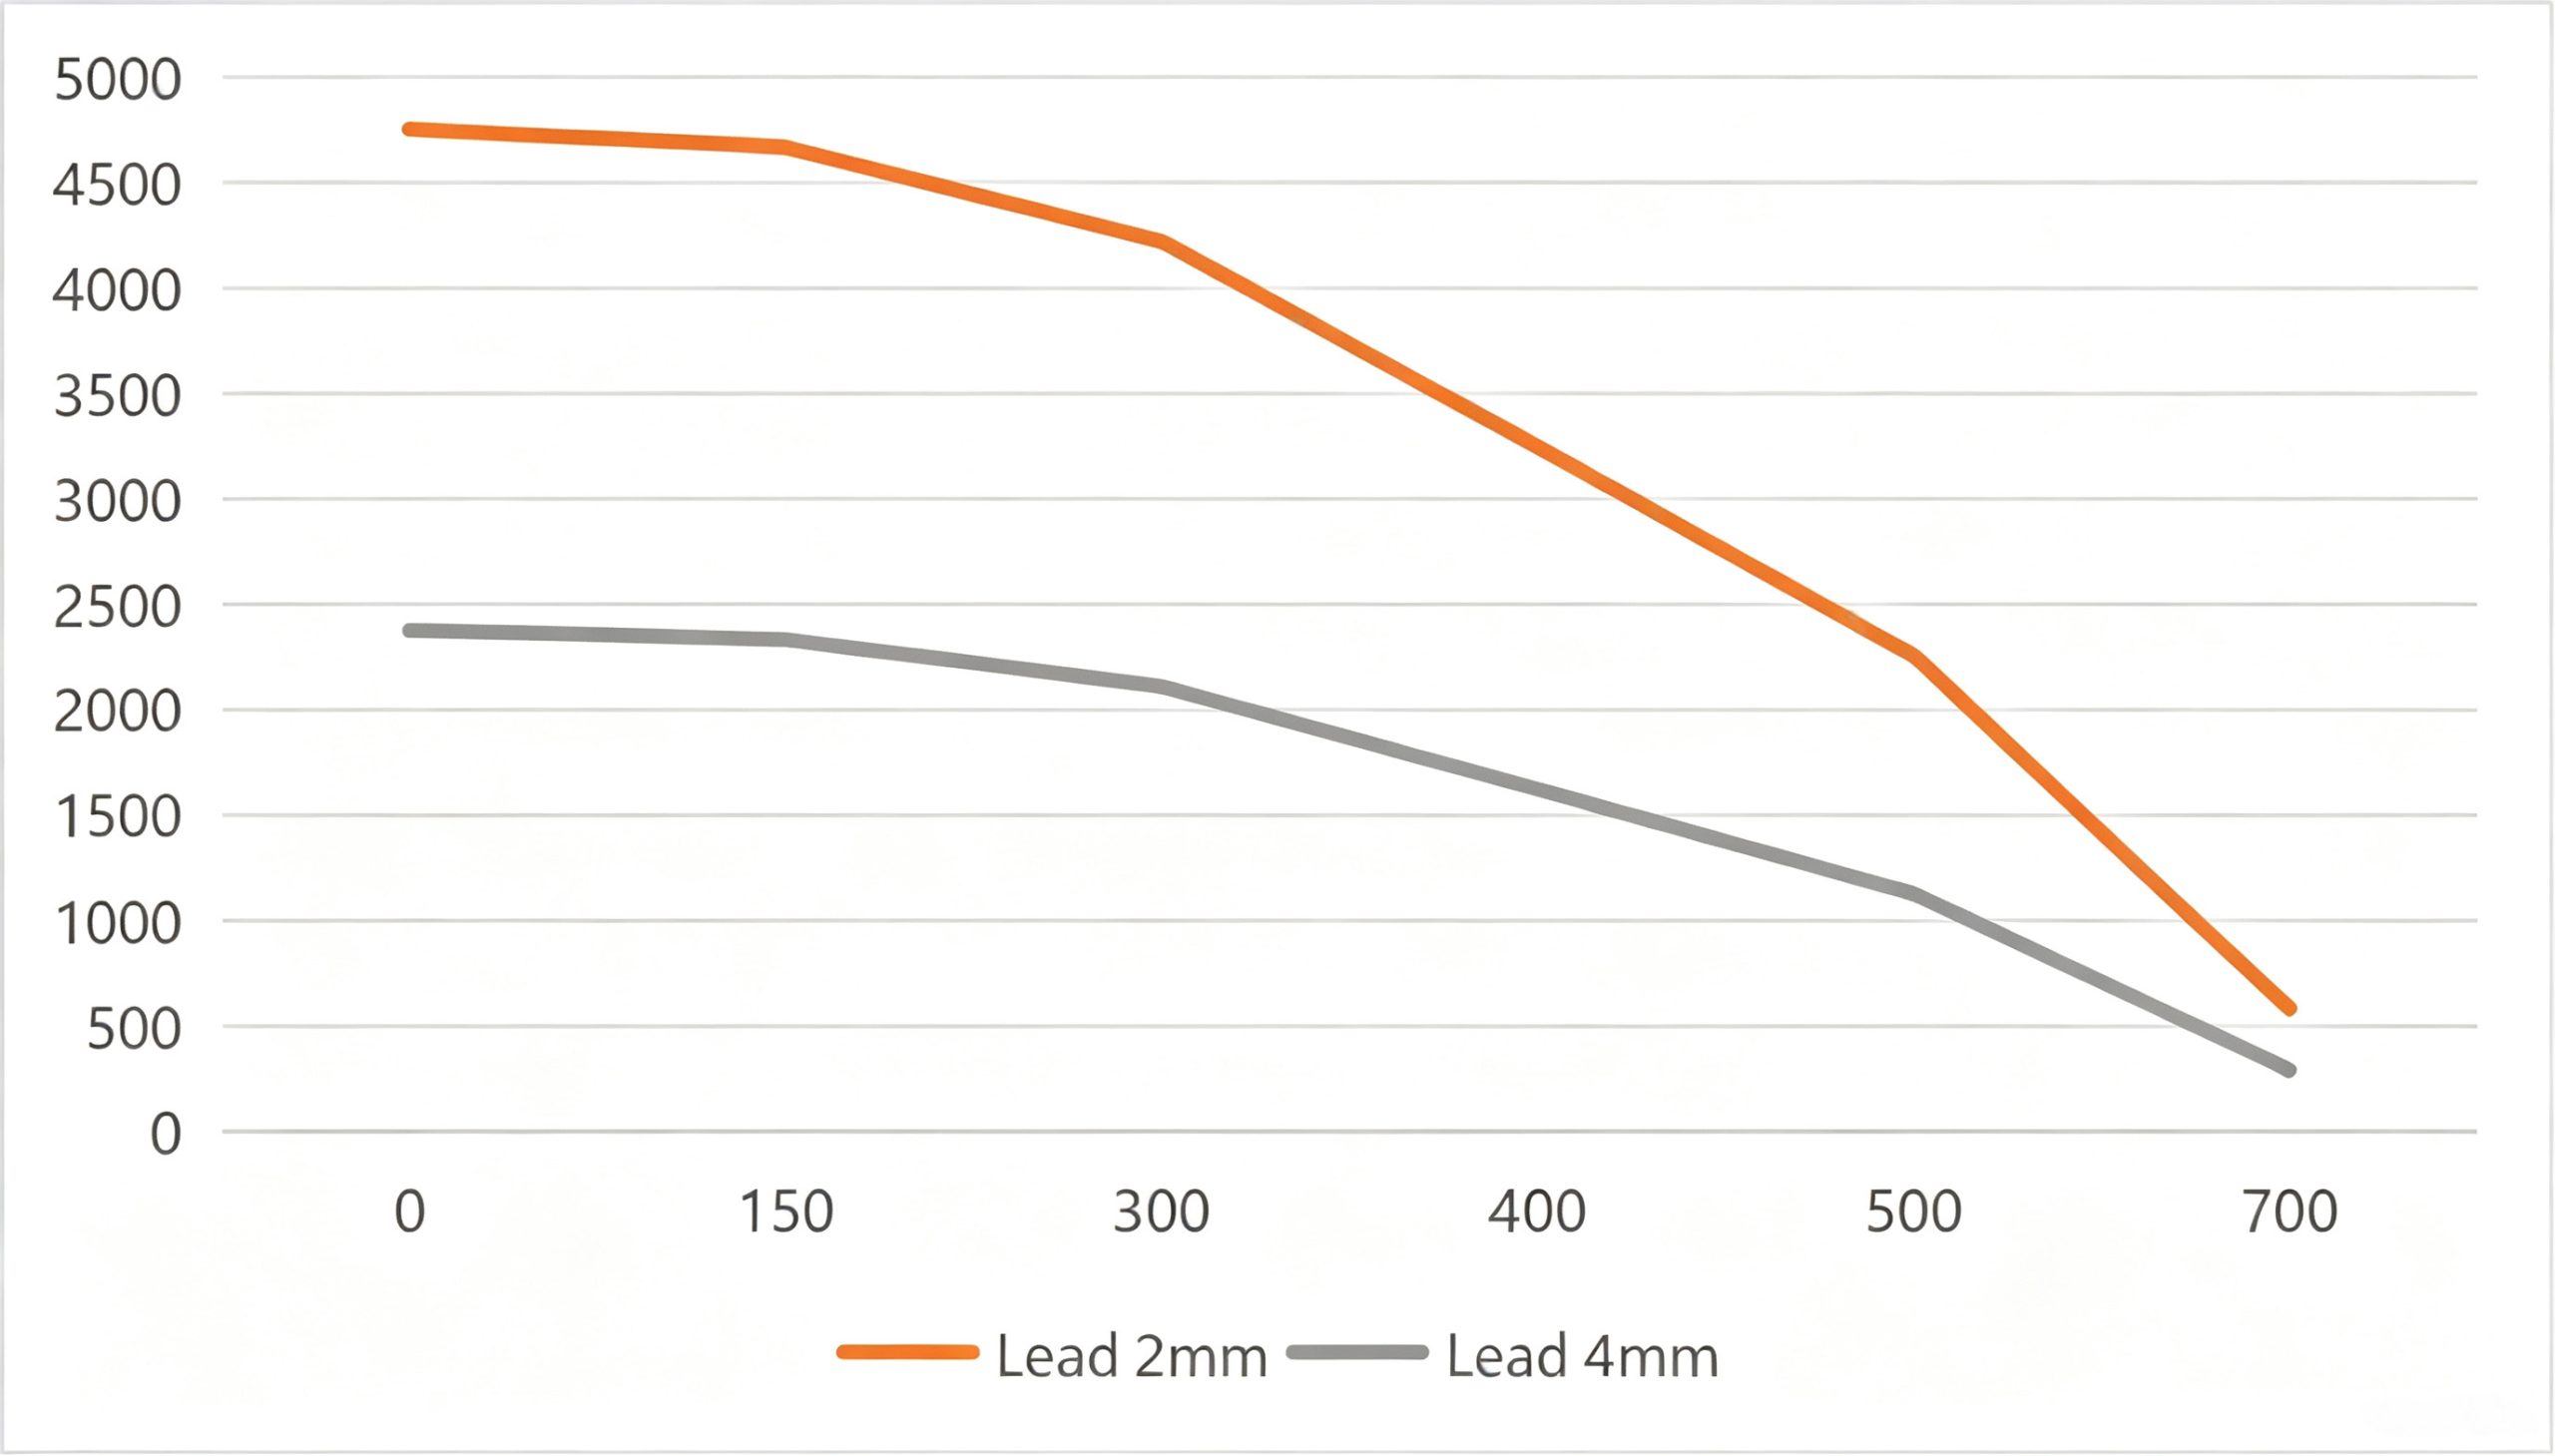
Torque curve
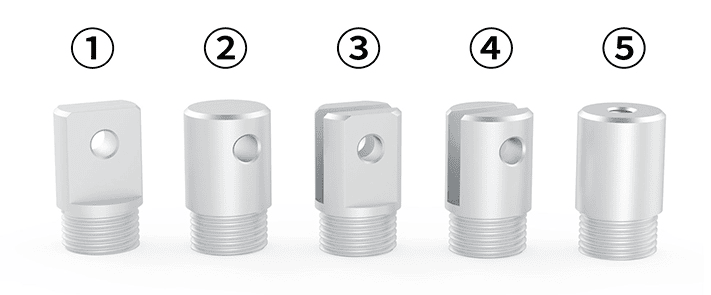
Pushrod Joint Types
Functional features
| Function |
Describe
|
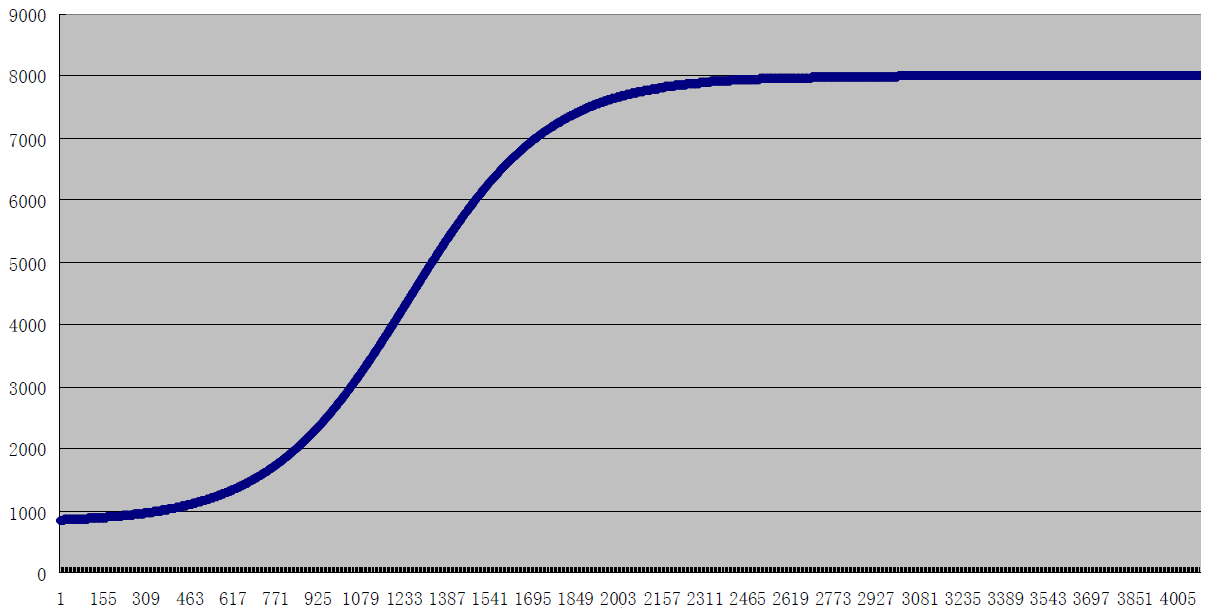
| S-curve accel/decel automatic control |
Support start speed, stop speed, acceleration, and deceleration. Acceleration/deceleration supports 8‑level adjustment (see simulation curves).
|
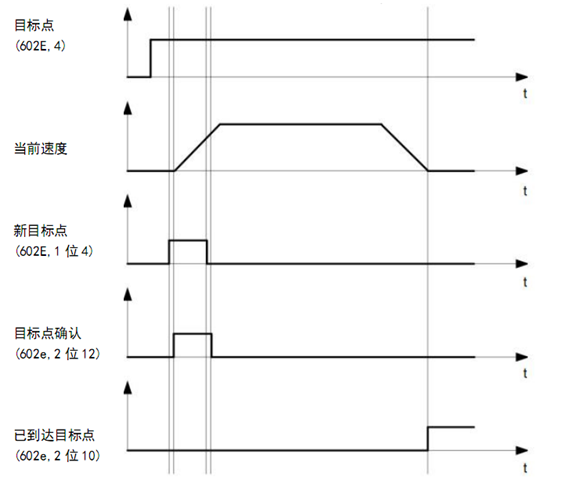
| PP mode |
During PP mode operation, the host can write a new set of parameters. The actuator can either smoothly transition to the new parameters while continuing the current motion, or finish the current motion cycle first and then apply the new parameters (see illustration).
|
Pre-purchase Considerations
|
Pre-purchase Considerations
|
|
| ① |
First, determine the load conditions of your equipment. Then, proceed to the next step of sizing based on the required thrust and pull forces.
|
| ② | Next, determine the required stroke length to achieve the desired motion – specifically, the extension distance the actuator rod needs to travel.
|
| ③ |
For speed selection, keep in mind that speed is load‑dependent – higher loads result in lower speeds, and in general, speed is inversely proportional to load.
|
| ④ |
Determine the mounting dimensions and make sure they fit reasonably within the available space of your equipment.
|